
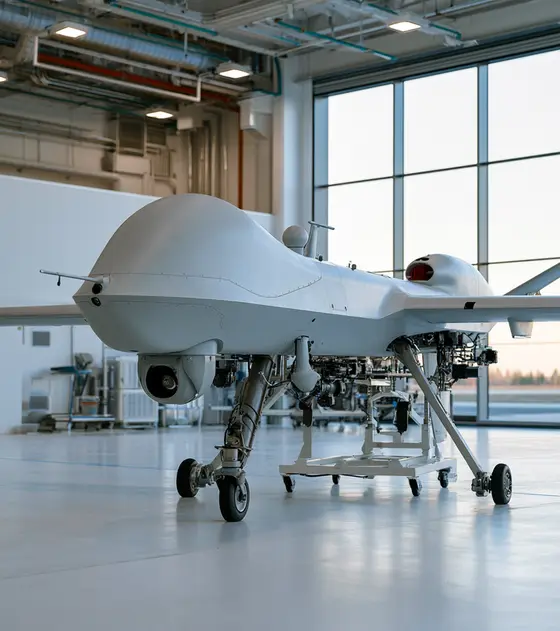
In short:Military UAV motion parts must meet the same gram-by-gram mass budget as commercial drones, and also pass a tailored MIL-STD-810 and MIL-STD-461 programme on a 28 V airframe supply. Choose propulsion motors, control-surface actuators and gimbal axes that already have that test evidence, and check that their supply chain suits a defence buyer.
Typical requirements
| Control-surface servo actuator (example) | 2.7 Nm continuous, 5.0 Nm peak, 270 g, 28 V DC (12–32 V range) |
|---|---|
| Servo actuator operating temperature (example) | −30 °C to +70 °C standard; −70 °C version on request |
| Servo actuator speed (example) | 200 °/s at rated torque |
| Gimbal slew rate (example) | 200 °/s with continuous pan |
| Miniature gimbal slip ring | 20–60 circuits at 0.8 A in a 12.7 mm (0.50 in) barrel |
| Actuator supply variants (example) | 14 V DC and 28 V DC ratings within a 10–30 V range |
Machinery we specify motion for
- Multirotor and VTOL lift propulsion
- Fixed-wing pusher and tractor propulsion
- Control-surface servo actuators
- Stabilised EO/IR gimbals
- Payload bay doors and release hooks
- Landing gear and folding wing locks
- Engine starter-generators
- Catapult launch and recovery winches
Military and tactical UAVs range from hand-launched quadcopters to fixed-wing and VTOL aircraft with runway, catapult or vertical launch. Their motion systems are the same four groups as any drone: propulsion, flight control actuation, stabilised payloads and payload or recovery mechanisms. What changes is the evidence. Every part has to prove it survives the environmental and EMC profile written into the programme, and the supply chain has to satisfy a defence customer.
For the commercial side of the same problem, including motor KV, thrust tables and hover efficiency, see our drones and UAVs page. This page focuses on what changes for defence.
Propulsion: BLDC motors for military UAVs
Multirotor and VTOL lift uses outrunner brushless motors; fixed-wing pushers and tractor propellers use outrunners or inrunners; hybrid aircraft add a starter-generator on the engine. Plettenberg, a German UAV motor maker, frames the trade-off well: outrunners give the best power-to-weight, while closed-housing inrunners give better robustness in harsh environments, and it qualifies COTS motors to MIL-STD-810H.
What to specify beyond thrust and power:
- Sealing and housing. Sand and dust (MIL-STD-810H Method 510) and rain or salt fog attack open outrunner bearings and windings. Decide whether an open motor with a protective coating is enough or whether you need a closed inrunner.
- Thermal margin at high ambient and altitude, where thinner air cools less. Ask for the temperature rise at your continuous power, not just peak ratings.
- Magnet supply. Plettenberg notes that over 90% of rare-earth magnet production is concentrated in China and offers non-Chinese magnet options for buyers with NDAA or DFARS requirements. Raise this at RFQ stage if it applies.
- Motor controller EMC. ESCs switch fast at high current. Shielded motor leads, short phase cables and input filtering decide whether you pass MIL-STD-461 CE102 and RE102.
On hybrid and engine-driven aircraft, the electric machine on the engine is often a starter-generator. Plettenberg describes a starter-generator control unit that handles power conversion and regulation, battery charging, avionics supply and engine start, so specify the generator and its controller together, with the bus voltage, peak start torque and continuous electrical output you need.
Size motors with servo and stepper motors and compare low-voltage drives on servo drives.
Control-surface servo actuators
Fixed-wing and VTOL military drones move ailerons, elevators, rudders, flaps and throttle with compact electromechanical servo actuators. Volz’s DA 26 is a representative 28 V brushless unit: 2.7 Nm continuous and 5.0 Nm peak, 200 °/s at rated torque, 270 g, IP67, −30 °C to +70 °C as standard (−70 °C on request), over 100 hours salt spray, vibration and shock tested to MIL-STD-810F and 810G, and over 3 million endurance cycles. The smaller DA 20-T is 20 mm wide, runs from 10–30 V, and was qualified to MIL-STD-810F and 810G with a 1,000-hour vibration test.
How to size one:
- Calculate maximum hinge moment at the highest dynamic pressure and full deflection.
- Add margin for gusts, ice and linkage friction (a rule of thumb is to keep continuous operation below about half of peak torque).
- Check speed at that torque against the flight control law’s required deflection rate.
- Decide fail behaviour: hold position, centre, or go free, and whether you need dual-redundant motors or position sensors.
- Specify the interface (PWM, RS-485, CAN) and position feedback; contactless sensors avoid potentiometer wear.
EO/IR gimbals and payload axes
Surveillance payloads sit in stabilised gimbals, normally with direct-drive brushless torque motors on each axis. Allied Motion, for example, describes custom brushless torque motors for a UAV gimbal with continuous pan, +40°/−220° tilt and a 200 °/s slew rate. Continuous pan needs a slip ring: low-torque gold-on-gold miniature capsules such as Moog’s AC264 family pack 20–60 circuits at 0.8 A into a 12.7 mm barrel with a starting torque of 2 g·cm or less per circuit. For video and Ethernet, use Ethernet slip rings or an electro-optic hybrid. Our EO/IR gimbal page covers motors, encoders and stabilisation in detail, and the gimbal and drone slip ring page covers the slip ring side.
Encoders must survive the airframe’s shock and vibration. Netzer’s VLP capacitive encoders, for example, are rated to 100 g for 6 ms shock and 20–2,000 Hz vibration, −40 °C to +105 °C.
Payload bays, launch and recovery
Payload bay doors, release hooks, landing gear and folding wing or arm locks use small linear actuators or geared servos. The questions are always the same: force and stroke, what happens on loss of power or signal, whether the mechanism must be backdrivable for ground loading, and how many cycles over the service life. Launch and recovery equipment on the ground (catapult rails, recovery winches, net or line capture systems) is closer to industrial machinery and can use rugged servo motors and drives with sealed connectors. See how to size a linear actuator.
Environment, EMC and qualification
- Environment. Military UAV programmes tailor MIL-STD-810H or DEF STAN 00-35. Typical methods are low pressure (altitude, 500), high and low temperature (501, 502), temperature shock (503), salt fog (509), sand and dust (510), vibration (514), shock (516) and icing (521). RTCA DO-160 is used where the airframe follows an airworthiness route.
- EMC. MIL-STD-461 (revision H since April 2026) or DEF STAN 59-411. Brushless drives with fast edges and long unshielded leads are the usual source of emissions near GNSS and datalink antennas.
- Weight. Count connectors, cable, brackets and drive electronics, not just the bare motor.
- Export control. Parts specially designed for military UAVs may be controlled under the UK Military List or dual-use lists. The supplier and exporter classify and license; tell them the end use early. See our defence and security overview.
Typical pitfalls
- Taking a commercial drone motor into a sand and salt environment without a sealed housing or coating.
- Sizing a control-surface servo on peak torque and then overheating it in sustained gusty flight.
- Forgetting slip ring drag on a lightweight gimbal pan axis.
- Treating EMC as an integration problem rather than a component specification.
- Not asking about magnet origin until a compliance review late in the programme.
Send us your airframe mass, supply voltage, hinge moments and payload axes, and our specialist engineering and supply partners can propose motors, actuators, slip rings and feedback with the qualification evidence you need.
Military drone motors for propulsion
Military drone motors start from the same thrust tables as commercial ones, then add evidence. Ask which MIL-STD-810H methods, procedures and levels the motor has passed, especially sand and dust, salt fog, vibration and shock, and whether the test covered the motor with its ESC. Decide between an open outrunner with protective coating and a closed housing. Ask for temperature rise at your continuous power at the highest ambient and altitude, because thin air cools less. Specify mass with leads, connector, bearing life and EMC behaviour of the motor and ESC pair. If the programme has country-of-origin or magnet sourcing rules, raise them at enquiry stage.
- Multirotor and VTOL UAVs: lift motors and ESCs
- Heavy-lift and cargo UAVs: high-thrust flat-wire motors
- Fixed-wing UAVs: pusher and tractor propulsion
- Tactical quadcopters: compact sealed outrunners
Available through our supply network
All servo and stepper motors →Specify servo and stepper motors for military drones and uavs →
Gimbal frameless motors for UAV payloads
Stabilised UAV payloads use direct-drive brushless torque motors on each axis, often as frameless kits built into the gimbal yoke to save mass and leave a hollow centre. Size each axis on peak torque to reject the airframe disturbance plus imbalance, slip ring and cable drag, and on RMS torque for heating inside a closed payload. Choose low-cogging designs for smooth slow tracking and ask for measured cogging rather than a qualitative claim. Specify outside diameter, axial length, bore, mass, winding voltage for the airframe bus, and the temperature range of the tailored environmental profile. Fit a winding temperature sensor on prototypes to check heating at peak torque.
- UAV EO/IR gimbals: pan, tilt and inner-axis direct drives
- Surveillance payloads: low-cogging continuous pan
- Antenna trackers on UAVs: compact pointing axes
- Ground control station trackers: direct-drive positioners
Available through our supply network
All frameless and torque motors →Specify frameless and torque motors for military drones and uavs →
UAV gimbal slip rings
Continuous pan on a UAV gimbal needs a slip ring with low, consistent drag torque, because it acts directly on a lightweight stabilised axis. Gold-on-gold capsules carry power and lower-rate control signals. If the payload streams HD video or sensor data over Ethernet, state the protocol, data rate, cable length and EMC environment, and ask for a bit error rate test on the actual configuration. Fibre and electrical hybrids handle bandwidth that copper cannot. Specify altitude, temperature range, vibration profile and drag torque at the cold end, where lubricants stiffen. Leave spare channels for the next sensor upgrade, which almost always needs more bandwidth.
- UAV EO/IR gimbals: power, video and Ethernet across continuous pan
- Surveillance payloads: compact low-drag capsules
- High-bandwidth sensor pods: fibre and electrical hybrids
- Tethered UAV winches: power and data on the drum
Available through our supply network
All slip rings →Specify slip rings for military drones and uavs →
Encoders for UAV gimbals and actuators
UAV gimbal axes and control actuators need absolute feedback that survives the airframe's shock and vibration and adds very little mass. Thin ring encoders and capacitive or inductive kits fit around the hollow shaft of a frameless motor; contactless sensors also remove the wear of the potentiometers found in older servo actuators. Specify resolution, accuracy against the pointing budget, latency, interface, supply voltage and mass with cable. Check shock and vibration ratings against the tailored MIL-STD-810H profile, and the temperature range for cold soak at altitude. Capacitive encoders are insensitive to magnetic fields from nearby motor magnets and power wiring.
- Gimbal axes: absolute angle for stabilisation and pointing
- Control-surface actuators: contactless output position
- Payload mechanisms: position sensing
- Launch and recovery equipment: rugged position feedback
Available through our supply network
All encoders and feedback →Specify encoders and feedback for military drones and uavs →
Lightweight servo drives for military UAVs
Gimbal and actuator drives on a military UAV must be light, efficient and qualified to the same environmental and EMC profile as the airframe. Board-level drives run directly from the flight battery or the 28 V airframe bus and close the current loop quickly for smooth stabilisation. Specify input voltage range including transients, continuous and peak current, encoder interfaces, CANopen or EtherCAT, mass and footprint. Drives with fast switching edges and long leads are the usual source of emissions near GNSS and datalink antennas, so shield phase leads, keep them short and filter the input to pass MIL-STD-461 CE102 and RE102 or the DEF STAN 59-411 equivalent.
- UAV gimbals: compact axis drives inside the payload
- Payload and recovery mechanisms: small actuator drives
- Unmanned ground and aerial vehicles: low-voltage servo axes
- Ground antenna trackers: rugged pointing drives
Available through our supply network
All servo drives →Specify servo drives for military drones and uavs →
Payload and recovery actuators for UAVs
Payload bay doors, release hooks, landing gear locks and folding wing or arm latches use small linear actuators or geared servos. Specify force and stroke, speed, the number of cycles over the service life, and what happens on loss of power or signal: hold position, release, or go free. A self-locking lead screw holds with power off but resists manual backdriving for ground loading, so decide which matters more. Check mass with cable and connector, the temperature range of the environmental profile, and ingress against rain, sand and salt. Linear stepper actuators give a simple, controllable stroke for light mechanisms; heavier ground equipment uses sealed industrial actuators.
- Payload bays: door and release hook actuation
- Landing gear and folding wings: lock and latch strokes
- Parachute recovery: release mechanisms
- Sensor deployment: extend and retract strokes
Available through our supply network
All linear actuators →Specify linear actuators for military drones and uavs →
Compact gearing for UAV mechanisms
Mechanisms that need more torque than a direct-drive motor can give within the mass budget, such as VTOL tilt drives, winches and delivery mechanisms, use compact high-ratio gearing. Strain-wave gear sets give zero backlash and a high ratio in one short stage, and integrated harmonic actuators package motor, gear, encoder and drive. Size on peak torque for gusts and landing loads, holding torque with power off, and mass. Check lubricant performance at the cold end of the environmental profile and at altitude, torsional stiffness if the mechanism sits in a control loop, and vibration ratings against rotor and propeller harmonics.
- VTOL tilt mechanisms: high-torque compact reduction
- Delivery and release systems: geared mechanisms
- Recovery winches: compact high-ratio drives
- Folding arm and wing locks: geared positioning
Available through our supply network
All gearboxes and harmonic drives →Specify gearboxes and harmonic drives for military drones and uavs →
Standards to have in view
- MIL-STD-810H (environmental engineering and laboratory tests)
- MIL-STD-461H (control of electromagnetic interference; supersedes MIL-STD-461G)
- RTCA DO-160 (environmental conditions and test procedures for airborne equipment)
- DEF STAN 00-35 (environmental handbook for defence materiel)
- DEF STAN 59-411 (electromagnetic compatibility)
- IEC 60529 (IP codes)
Which standards apply depends on the end product and its market. Your engineer will confirm what the component itself needs to meet.
Frequently asked questions
How are military drone motors different from commercial drone motors?
The electromagnetic design is often similar. The differences are qualification and supply: environmental testing to MIL-STD-810H, closed or sealed housings for sand, rain and salt, wider temperature ratings, EMC performance, quality systems such as EN 9100, and traceable materials. Magnet sourcing is now part of the specification; some suppliers offer non-Chinese magnet options for programmes with NDAA or DFARS requirements.
What torque does a UAV control-surface servo need?
Work it out from hinge moment: control surface area, chord, dynamic pressure at the highest airspeed and maximum deflection, plus a margin for gusts and icing. Then check speed at that torque. As a scale reference, Volz's 28 V DA 26 actuator gives 2.7 Nm continuous and 5.0 Nm peak at 270 g. Specify holding torque, backdrive behaviour on power loss and travel limits too.
Does a UAV gimbal slip ring need to pass gigabit Ethernet?
If the payload streams HD video or sensor data over Ethernet across a continuously rotating pan axis, yes. Miniature gold-on-gold capsules handle power and lower-rate signals; Ethernet-rated capsules or slip ring and FORJ hybrids handle higher bandwidth. State the protocol, data rate, cable length and EMC environment, and ask for a bit error rate test on the actual configuration.
What MIL-STD-810H methods apply to UAV actuators?
It depends on your tailored environmental profile, but most UAV programmes include high and low temperature, temperature shock, altitude, humidity, salt fog, sand and dust, vibration (Method 514), shock (Method 516) and often rain and icing. Ask suppliers which methods, procedures and levels each part has passed, and whether the test report covers the configuration you are buying.
Why use brushless rather than brushed actuators on a military UAV?
Brushless motors have no commutator wear or brush dust, run cooler for a given torque and generate less broadband electrical noise from brush arcing, which helps EMC. Combined with contactless position sensing, they also remove the wear mechanisms that limit life. Volz quotes over 3 million endurance cycles for its DA 26 brushless actuator.
What should I send for a military UAV motion enquiry?
Send maximum take-off mass, airframe type, propulsion power per motor and supply voltage, control-surface hinge moments and deflection rates, gimbal axes with payload mass and inertia, slip ring signals and data rates, environmental and EMC specifications, mass limits per component, expected production volumes and any restrictions on country of origin or magnet sourcing.
Sources
- Volz Servos: DA 26 brushless actuator datasheet
- Defense Advancement: Volz DA 20-T actuator
- Defense Advancement: key considerations for sourcing UAV motors and generators (Plettenberg)
- Allied Motion: motion control solutions for military aircraft
- Moog: aerospace and defence slip ring product catalogue
- Netzer: product catalogue 2025
- Systel: what is MIL-STD-810H?
- IB-Lenhardt: MIL-STD-461H published
Figures are summarised from the sources above and from manufacturers' published data on the date shown. Always confirm against the current datasheet for your exact part.