In short:Build the move profile first, then add up load, friction, acceleration and gravity forces for every segment, size the screw on cubic mean force for life and peak force for strength, choose the lead from the speed and motor rpm, and size the motor on peak and RMS torque using T = F × lead ÷ (2π × η).
The sizing sequence
Sizing an electric linear actuator is a chain, and each step feeds the next:
- Define the move profile: distance, time, speed and acceleration for every segment.
- Calculate the force in every segment: load, friction, acceleration and gravity.
- Check the screw: cubic mean force for life, peak force for static capacity, speed for critical speed.
- Choose the lead from speed and motor rpm.
- Convert force to motor torque, and check peak and RMS torque.
- Check holding, brake and duty.
Skipping to step 5 with a single “worst case” force is the most common reason actuators come out oversized, overheated or both.
Step 1: the trapezoidal move profile
For a move of distance d in time t, the 1/3 trapezoidal profile divides the time into equal thirds: accelerate, cruise, decelerate. Then:
- Peak speed: v = 1.5 × d / t
- Acceleration: a = v / (t / 3) = 4.5 × d / t²
- Distance while accelerating (and decelerating): d / 4 each; cruising: d / 2
A triangular profile (accelerate then decelerate, no cruise) gives the lowest acceleration for a given move but needs a peak speed of 2 × d / t. The 1/3 trapezoid trades a little acceleration for a much lower peak speed and is the usual starting point.
Write down every segment in a table, including dwells. A dwell with a vertical or inclined load, or a clamp holding force, is still a load on the motor.
Step 2: force components
For each segment, sum the axial forces the actuator must provide. THK’s ball screw method sets these out for horizontal and vertical axes (THK); for an incline at angle θ from horizontal, the same idea generalises:
| Component | Formula | Notes |
|---|---|---|
| Gravity (incline) | m × g × sin θ | θ = 0 for horizontal, 90° for vertical |
| Friction of the guide | μ × m × g × cos θ | Rolling guides are low friction; plain bearings are much higher |
| Acceleration | m × a | Positive when accelerating, negative when decelerating |
| Process force | F_p | Pressing, clamping, cutting, spring loads; note where in the stroke it acts |
| Seal and wiper drag | from the datasheet | Often significant on small actuators |
Sign the direction carefully. Going up an incline, gravity and friction both oppose the motion. Coming down, gravity helps and friction opposes, so the actuator often still pushes up the slope while moving down, just with less force. If the force ever changes sign, note it: THK calculates the mean load separately for each direction and uses the larger.
Step 3: RMS force, cubic mean force and duty
You need two different averages from the same cycle:
RMS force (time-weighted), for motor heat: F_rms = √( Σ Fᵢ² × tᵢ / Σ tᵢ )
Cubic mean force (distance-weighted), for screw life (THK): F_m = ( Σ Fᵢ³ × ℓᵢ / Σ ℓᵢ )^(1/3)
Holding force during a dwell counts towards RMS (the motor is producing torque) but not towards life (no distance is travelled).
Screw life is then L10 = (C / F_m)³ × 10⁶ revolutions, and the peak force must stay well inside the static rating, with THK’s minimum safety factor of 2 for smooth duty and 5 with vibration or impact. For the trade-offs between screw types, see ball screw vs roller screw.
Duty cycle is how the motor’s thermal limit appears on DC actuators that have no servo drive. Many are rated at a percentage of on-time; Thomson’s Electrak HD, for example, is rated at 25% duty at 25°C for most models in our catalogue data. If your cycle moves 50% of the time, that class of actuator is ruled out regardless of force. Servo actuators are sized on RMS torque instead.
Step 4: stroke and lead
Stroke: specify the working stroke plus margin at each end for over-travel, homing and mechanical tolerances. Do not let the actuator run onto its internal end stops in normal use.
Lead: the motor speed is n (rpm) = v (mm/s) × 60 / lead (mm). So the minimum lead is:
lead_min = v × 60 / n_max
Then consider the trade-offs:
- A coarser lead lowers motor speed, which helps critical speed and lets you use a slower, cheaper motor, but needs proportionally more torque and makes the axis easier to back-drive.
- A finer lead gives more force per Nm and finer resolution, but needs more rpm and may run into the screw’s critical speed.
Critical speed for a screw of root diameter dr and unsupported length L (both mm) is approximately nc = f × dr / L² × 10⁷ rpm, with f = 3.4 (fixed-free), 9.7 (supported-supported), 15.1 (fixed-supported) or 21.9 (fixed-fixed) (Engineers Edge). Keep operating speed below about 80% of it unless the supplier’s rating already includes that margin.
Step 5: motor torque from force, lead and efficiency
The torque to drive an axial force F through a screw of lead P is (Linear Motion Tips):
T = F × P / (2π × η)
with F in N, P in metres per revolution and T in Nm. (With P in millimetres, divide by 2,000π instead of 2π.) Typical efficiencies: ball screws 85–95%, roller screws 75–90%, Acme screws around 40% (Moog, Kollmorgen).
Add:
- Rotary inertia torque: (J_motor + J_coupling + J_screw) × α, where α = a × 2π / P (rad/s²). The moving mass is already in the force through m × a; do not count it twice. A solid steel screw’s inertia is J = π × ρ × L × d⁴ / 32, with ρ = 7,850 kg/m³.
- Preload and bearing drag: from the screw datasheet.
- Gearbox or belt: divide torque by ratio and efficiency; multiply speed by ratio.
For the inertia ratio, the load’s reflected inertia is m × (P / 2π)², plus the screw. Compare it with the rotor inertia and keep within the drive maker’s guidance.
When the load drives the screw (lowering a load, or decelerating), the motor torque is roughly F × P × η / (2π) instead. Using the driving formula throughout is conservative.
Size the motor so that the peak torque at its speed sits inside the motor’s intermittent region, and the RMS torque sits below its continuous rating at the RMS speed.
Step 6: holding and brakes
Ball and roller screws are efficient enough to back-drive. Any vertical or inclined axis, and any axis that must hold a clamp force, needs a spring-applied, power-off brake. Size the brake on the back-driving torque F × P × η / (2π), with a margin of 1.5 to 2 times as common practice. Holding on the brake during long dwells also takes the dwell out of the motor’s RMS torque.
Worked example: an inclined transfer axis
Application: a servo-driven rod actuator pushes a 40 kg carriage up a 30° incline on a rolling linear guide (μ assumed 0.01).
- Stroke 500 mm. Up move in 1.0 s, dwell 1.0 s, down move in 1.0 s, dwell 1.0 s. Cycle 4.0 s.
- 16 hours a day, 250 days a year. Target screw life 5 years.
- Servo motor top speed 3,000 rpm. Ball screw efficiency 0.9.
Move profile (1/3 trapezoid):
- v = 1.5 × 0.5 / 1.0 = 0.75 m/s
- a = 0.75 / 0.333 = 2.25 m/s²
- Accelerate 125 mm, cruise 250 mm, decelerate 125 mm, each 0.333 s
Force components:
- Gravity: 40 × 9.81 × sin 30° = 196.2 N
- Friction: 0.01 × 40 × 9.81 × cos 30° = 3.4 N
- Acceleration: 40 × 2.25 = 90 N
Segment forces (positive = pushing up the slope):
| Segment | Calculation | Force | Time | Distance |
|---|---|---|---|---|
| Up, accelerate | 196.2 + 3.4 + 90 | 289.6 N | 0.333 s | 125 mm |
| Up, cruise | 196.2 + 3.4 | 199.6 N | 0.333 s | 250 mm |
| Up, decelerate | 196.2 + 3.4 − 90 | 109.6 N | 0.333 s | 125 mm |
| Dwell, top | 196.2 | 196.2 N | 1.0 s | 0 |
| Down, accelerate | 196.2 − 3.4 − 90 | 102.8 N | 0.333 s | 125 mm |
| Down, cruise | 196.2 − 3.4 | 192.8 N | 0.333 s | 250 mm |
| Down, decelerate | 196.2 − 3.4 + 90 | 282.8 N | 0.333 s | 125 mm |
| Dwell, bottom | 196.2 | 196.2 N | 1.0 s | 0 |
The force never changes sign, so one mean covers the whole cycle.
Averages:
- Cubic mean (distance-weighted): F_m ≈ 215 N
- RMS (time-weighted), holding on the motor during dwells: 203 N
- Peak: 290 N
Lead: lead_min = 750 × 60 / 3,000 = 15 mm. Choose a 20 mm lead: motor speed = 750 × 60 / 20 = 2,250 rpm.
Critical speed check: assuming a 17 mm root diameter and 650 mm unsupported, fixed-supported: nc ≈ 15.1 × 17 / 650² × 10⁷ ≈ 6,080 rpm; 80% is about 4,860 rpm. 2,250 rpm is fine.
Screw life:
- Cycles a year: 900 an hour × 16 × 250 = 3.6 million; 1.0 m of travel each
- Five years: 18,000 km = 18 × 10⁹ mm / 20 mm = 9 × 10⁸ revolutions
- Required C = F_m × (900)^(1/3) = 215 × 9.65 ≈ 2.1 kN (2.5 kN with a 1.2 load factor). Any 20 mm ball screw meets this many times over; life is not the constraint here.
Motor torque (T = F × 0.020 / (2π × 0.9), plus rotary inertia):
- Rotary inertia: screw (20 mm × 700 mm steel) J = π × 7,850 × 0.7 × 0.02⁴ / 32 ≈ 0.86 × 10⁻⁴ kg·m², plus an assumed rotor inertia of 0.6 × 10⁻⁴ kg·m². α = 2.25 × 2π / 0.020 ≈ 707 rad/s², giving 0.10 Nm while accelerating or decelerating.
- Peak: 289.6 × 0.00354 + 0.10 ≈ 1.13 Nm at 2,250 rpm (up, accelerating)
- Holding: 196.2 × 0.00354 ≈ 0.69 Nm
- RMS over the cycle, holding on the motor: 0.74 Nm
- RMS with the brake holding during dwells: 0.55 Nm
Motor choice: a 400 W class servo (about 1.27 Nm continuous at 3,000 rpm, since P = T × ω) with a peak of roughly three times that covers 1.13 Nm peak and 0.74 Nm RMS with margin. Reflected inertia is 40 × (0.020 / 2π)² ≈ 4.1 × 10⁻⁴ kg·m², plus the screw, about 8:1 against the assumed rotor; a comfortable ratio.
Brake: back-driving torque at the motor = 196.2 × 0.020 × 0.9 / (2π) ≈ 0.56 Nm. Specify a power-off brake of at least 1.1 Nm (2 times margin).
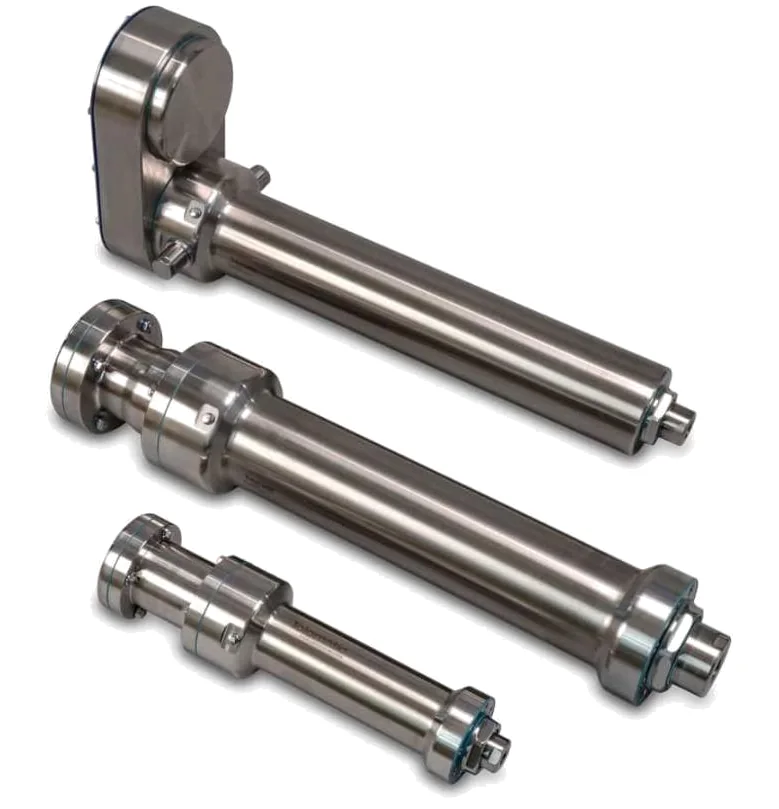
Duty: the axis moves 50% of the time and holds the rest, so a DC actuator rated at 25% duty is ruled out. A servo rod actuator suits. Candidates include the Tolomatic ERD (stainless, up to 2,224 N and 20 mm or 25.4 mm leads in our catalogue data) or the Tolomatic IMA integrated servo actuator. For high-force versions of the same calculation, roller screw units like the Exlar GTX apply.
What changes the answer: with a 10 mm lead, the motor would need 4,500 rpm, beyond a 3,000 rpm servo. With a 25.4 mm lead the motor runs at about 1,770 rpm but needs 27% more torque. Doubling the mass to 80 kg roughly doubles every torque and still leaves life comfortable.
Common mistakes
- Sizing on one worst-case force instead of segment by segment.
- Counting the moving mass twice, once in m × a and again as reflected inertia.
- Forgetting holding force in the RMS, especially on inclined and vertical axes.
- Using RMS force for life or cubic mean force for the motor.
- Choosing a fine lead for force and then running past critical speed.
- Ignoring duty limits on DC actuators.
- Allowing side load on the rod. Guide the load externally.
Checklist
Send these to our engineers, or enter them in the spec builder. Tolomatic’s application worksheet asks for much the same:
- Moving mass, orientation and incline angle
- Process forces, where in the stroke they act, and any impact or jam forces
- Stroke, and each move’s distance and time, with dwell times
- Cycle rate, hours per day, days per year and required life
- Accuracy and repeatability needed
- Holding requirement with power off
- How the load is guided, and any side load on the rod
- Supply voltage (24/48 V DC or mains), drive and fieldbus
- Mounting style and envelope
- Environment: temperature, washdown, IP rating, contamination
See also the linear actuators overview and our hydraulic to electric conversion guide.
Frequently asked questions
What information do I need to size a linear actuator?
You need the moving mass, orientation or incline angle, any process force and where in the stroke it acts, the stroke, the move distance and time for each move, dwell times, cycles per hour and hours per year, required life, accuracy, and whether the load must be held with power off. Add the environment and the supply voltage, and a supplier can size screw, motor and drive properly.
How do I calculate motor torque for a screw-driven actuator?
Torque to drive the load is T = F × lead ÷ (2π × η), with force in newtons, lead in metres per revolution and η the screw efficiency, giving Nm. Add the torque to accelerate the motor rotor, coupling and screw, which is their combined inertia multiplied by angular acceleration. Add the screw's preload and bearing drag from the datasheet. Then check peak and RMS torque against the motor's ratings.
What is the 1/3 trapezoidal move profile?
It splits each move into equal thirds of time for accelerating, running at constant speed and decelerating. Peak speed is then 1.5 times the average speed (distance divided by move time), and acceleration is peak speed divided by one third of the move time. It is a good compromise between peak speed and peak acceleration and is the usual starting point for sizing.
What is the difference between RMS force and cubic mean force?
RMS force, weighted by time, is used for the motor's thermal sizing because motor heating depends on current squared. Cubic mean force, weighted by distance travelled, is used for screw life because rolling contact fatigue follows a cube law. They are different numbers from the same cycle, and you need both. Holding force during a dwell counts for RMS but not for screw life.
How do I choose the screw lead?
Divide the peak linear speed by the motor's usable speed to get the minimum lead, then pick the next standard lead. A coarser lead runs the motor slower and helps critical speed, but needs more torque and back-drives more easily. A finer lead gives more force per Nm and finer resolution, but needs more rpm. Check the result against the screw's critical speed and the motor's torque-speed curve.
What does duty cycle mean for an electric actuator?
Duty cycle is the proportion of time the actuator is moving or loaded. Many DC actuators have a stated limit, for example 25% at 25°C for some Thomson Electrak HD models, because their motors have no active thermal management. Servo-driven actuators are sized on RMS torque instead, so they can run continuously if the RMS stays within the motor's continuous rating.
Sources
- THK: Ball screw selection, axial load, life and static safety factor (A15-46)
- Linear Motion Tips: How to calculate motor drive torque for ball screws
- Kollmorgen: Application sizing guide
- Moog: Planetary roller screws catalogue
- Engineers Edge: Ball screw critical speed calculator
- Tolomatic: Electric rod-style actuator application worksheet
Figures are summarised from the sources above and from manufacturers' published data on the date shown. Always confirm against the current datasheet for your exact part.