
Typical requirements
| Turret slip ring power rings | 150–450 A per power ring at vehicle voltages (18–37 V DC) |
|---|---|
| Turret slip ring signal circuits | 12 to 238 circuits at 2–5 A |
| Turret slip ring data | MIL-STD-1553, RS-170 video, 100 Mbit and gigabit Ethernet |
| Turret drive performance (published example) | Under 0.3 mrad/s slow tracking; 1 rad/s maximum; 2 rad/s² acceleration |
| Stabilisation quality (published example) | 0.3 mrad (1σ) |
| Encoder shock rating (example) | 100 g for 11 ms (MIL-STD-810G) |
Machinery we specify motion for
- Remote weapon station azimuth and elevation axes
- Vehicle turret traverse drives
- Turret ring slip rings
- Stabilised sight and sensor mounts
- Manual backup drives
- Naval and fixed-site mounts
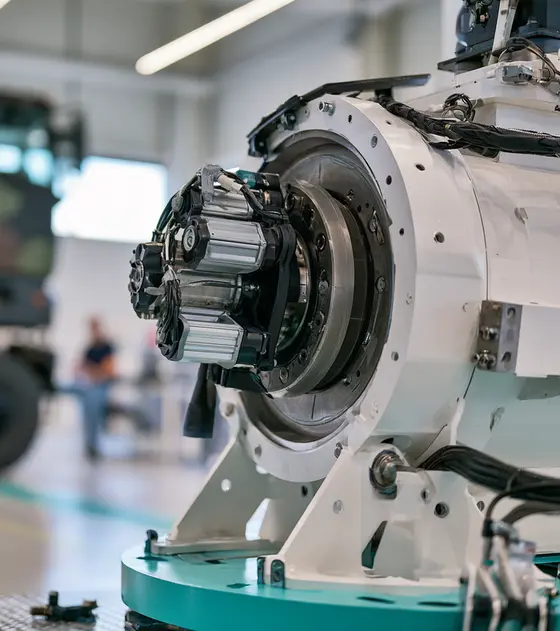
This page covers turrets and remote weapon stations strictly at component level: the slip rings, motors, gearing, encoders and drives that move a two-axis mount on a vehicle, vessel or fixed site. Whatever the payload, the motion problem is the same. A heavy, often unbalanced mass must slew quickly, hold a steady line of sight while the platform pitches and rolls, rotate continuously in azimuth, and survive shock, vibration, cold, heat, sand and water for years on a noisy vehicle supply.
Large-bore turret slip rings: power, video and Ethernet
Continuous azimuth rotation means everything crossing the turret ring goes through a slip ring, usually a through-bore unit sized to the ring opening. Moog’s published vehicular and turret slip rings illustrate what a remote weapon station slip ring has to carry:
| Model | Power rings | Signal circuits | Data and extras |
|---|---|---|---|
| AC3497 | 1 × 150 A | 12 × 5 A | Dual cam |
| VSR-4994 | 4 × 200 A, 24 V DC | 86 × 2–4 A | NBC air channel, 2 × MIL-STD-1553, 8 × RS-170 video |
| VSR-6057 | 2 × 250 A, 18–37 V DC | 238 × 2–4 A | High isolation concentric rings for EMI |
| VSR-6772 | 2 rings, 450 A and 75 A, 28 V DC | 150 | 100 Mbit Ethernet, resolver, pneumatic and hydraulic joint |
| VSR-7001 | 150 A, 120 A, 80 A, 13 A at 20–33 V DC | Twinax, coax | Gigabit Ethernet, RS-170 video, air channel, immersible to 1 m |
Source: Moog aerospace and defence slip ring catalogue. Moog lists gold-on-gold contacts, EMI shielding, full environmental sealing and military shock and vibration capability across the range.
What to state when specifying: bore and envelope, current per power ring and total, voltage, number and type of signal circuits, every data channel with protocol and rate, video format, any fluid or air passage, sealing (including immersion if the vehicle fords), and EMI isolation between power and signal. Read how to specify a slip ring, Ethernet through slip rings and our defence turret slip ring page, and see rugged military slip rings.
Torque motors and gearing for azimuth and elevation
Two drive architectures dominate.
| Architecture | How it works | Strengths | Watch out for |
|---|---|---|---|
| Geared turret drive | Servo motor and reduction drive a pinion on the ring gear | Compact motor, high output torque, easy manual backup | Backlash, gear compliance, wear; anti-backlash pinions or preload needed for stabilisation |
| Direct drive | Large frameless torque motor built into the ring or trunnion | No backlash, high stiffness, quiet, few wearing parts | Motor diameter and mass, heat in a sealed space, cost |
Kollmorgen describes its frameless KBM, TBM and RBE series for weapon stations; the RBE is a high-torque, low-speed pancake format that removes the shaft, bearings, endbells and couplings. For housed motors it offers a rugged servo range rated to MIL-STD-810E and sealed to IP67, with a stainless shaft and chemical agent-resistant paint. See frameless torque motors, frameless motor sizing and, for geared axes, harmonic vs planetary vs cycloidal and gearboxes.
How to size an axis:
- Calculate payload inertia about each axis, including cradle and cabling, and any static imbalance (elevation axes are rarely balanced).
- Set acceleration and speed from the slew requirement. As a published reference, one turret drive supplier quotes maximum speed of 1 rad/s and acceleration of 2 rad/s².
- Torque = inertia × acceleration + imbalance torque + friction + slip ring drag + margin for vehicle motion and wind.
- Check stiffness: the first structural resonance of motor, gearing and structure must sit well above the stabilisation loop bandwidth.
- Check thermal behaviour for the duty cycle inside a sealed housing.
Absolute encoders and feedback
Each axis needs an absolute encoder on the axis itself, so position is valid at power-up and no gear train sits between sensor and load. High-resolution ring encoders, capacitive and inductive kits, and resolvers all appear. Netzer’s encapsulated DS series, for example, offers up to 23-bit resolution with 100 g for 11 ms shock and 20–2,000 Hz vibration ratings under MIL-STD-810G. Large-bore inductive kits such as the Midi Ultra IncOder suit the hollow turret centre. Compare options in absolute vs incremental encoders.
Stabilisation loop requirements, in general terms
A stabilised mount uses gyroscopes to measure platform motion and drives the axes to cancel it. The published turret drive figures above include slow-speed tracking below 0.3 mrad/s and stabilisation of 0.3 mrad (1σ), with gyros added to an electric drive and RS-422, RS-485 or CAN interfaces. For component selection, the loop needs:
- High stiffness and low backlash between motor and load.
- Low torque ripple and cogging for smooth slow tracking.
- Fast current loop and adequate peak current in the servo drive.
- Low-noise, high-resolution feedback with low latency.
- Low, consistent slip ring drag torque that does not vary with temperature.
Shock, vibration, power and EMC
- Shock and vibration. Tracked and wheeled vehicles produce severe vibration, and the mount sees additional transient shock in use. MIL-STD-810H vibration (Method 514), shock (516) and gunfire shock (519) are common in tailored test programmes; UK programmes may use DEF STAN 00-35.
- Vehicle power. MIL-STD-1275E sets 20–33 V steady state and injected ±250 V spike tests on 28 V vehicles. Size drive input stages for surges and cranking dips.
- EMC. MIL-STD-461 or DEF STAN 59-411. High-current PWM drives inside a turret are a strong emission source; shielding and the slip ring’s isolation between power and signal rings matter.
- Sealing and NBC. Turret seals and slip ring air channels support NBC overpressure on many vehicles.
- Export control. Turret and weapon station components specially designed for military use are typically controlled; see the defence and security overview.
Typical pitfalls
- Under-sizing elevation torque by ignoring imbalance and vehicle pitch.
- Choosing a slip ring by circuit count alone without checking EMI isolation, data rates and drag torque.
- Placing the encoder on the motor of a geared axis and expecting the load to follow.
- Leaving vehicle supply transients to the system integrator.
- Ignoring heat in a sealed turret on a hot day.
Send axis inertias, speeds, bore, circuits and environment, and our engineers can propose slip rings, torque motors, gearing and feedback for the mount.
Remote weapon station slip rings
Everything that crosses the continuously rotating azimuth axis goes through the turret slip ring: high-current DC power for drives and payloads, control and sensor signals, video, data bus and Ethernet, and on some designs an NBC or cooling air channel. Specify bore and envelope, current per power ring and in total, voltage, signal circuits by type, every data channel with protocol and rate, video format, air or fluid passages, sealing including immersion for fording, and EMI isolation between power and signal rings. Choose by drag torque and its variation with temperature as well as circuit count, because drag acts on the stabilised axis. Agree life and brush inspection intervals.
- Remote weapon stations: power, video and Ethernet across azimuth
- Vehicle turrets: high-current through-bore turret ring slip rings
- NBC-protected turrets: air channels across the ring
- Naval and fixed-site mounts: sealed slip rings
Available through our supply network
All slip rings →Specify slip rings for turrets and remote weapon stations →
Torque motors for turret drives
A direct-drive frameless torque motor built into the turret ring or trunnion removes backlash and gives high stiffness with few wearing parts, at the cost of motor diameter, mass and heat in a sealed space. Size it from payload inertia times the required acceleration, plus imbalance, friction and slip ring drag, with margin for vehicle motion and wind; one published turret drive quotes 2 rad/s² acceleration and 1 rad/s maximum speed. Then check that the first structural resonance of motor, mount and structure sits well above the stabilisation loop bandwidth. Low cogging and torque ripple give smooth slow motion. Specify bore, envelope, bus voltage and temperature range.
- Remote weapon stations: direct-drive azimuth and elevation
- Turret rings: large-bore frameless traverse motors
- Stabilised sight mounts: low-cogging axes
- Fixed-site mounts: high-stiffness positioning
Available through our supply network
All frameless and torque motors →Specify frameless and torque motors for turrets and remote weapon stations →
Gearing for turret traverse and elevation
A geared turret drive uses a servo motor and reduction to drive a pinion on the ring gear, giving high output torque from a compact motor and an easy route for manual backup. The gearbox output bearing carries the pinion separating force, so choose a gearhead rated for high radial load. Backlash and compliance limit stabilisation, so use anti-backlash pinions, preload or two motors biased against each other. Specify output torque, shock and emergency stop torque, radial load, torsional stiffness, backlash, lubricant temperature range and sealing. Elevation axes are rarely balanced, so include the imbalance torque at the worst vehicle pitch when sizing.
- Turret traverse: pinion drives on the ring gear
- Elevation axes: high-torque low-backlash reduction
- Manual backup drives: geared hand drive paths
- Compact sensor mounts: hollow-shaft reducers
Available through our supply network
All gearboxes and harmonic drives →Specify gearboxes and harmonic drives for turrets and remote weapon stations →
Absolute encoders for turret axes
Each turret axis needs an absolute encoder on the axis itself, so position is valid at power-up and no gear train sits between sensor and load. Large-bore ring encoders and capacitive or inductive kits fit around the hollow turret centre with room for the slip ring. Check shock and vibration ratings against the vehicle profile: one encapsulated encoder on this page is rated to 100 g for 11 ms under MIL-STD-810G. Specify bore, accuracy after installation, resolution, latency, interface (SSI or BiSS-C), temperature range and EMC immunity next to high-current PWM drives. Placing the encoder on the motor of a geared axis leaves backlash outside the loop.
- Turret azimuth: large-bore absolute feedback
- Elevation axes: absolute angle at the trunnion
- Stabilised sight mounts: high-resolution low-latency feedback
- Gearbox motor feedback: commutation and velocity
Available through our supply network
All encoders and feedback →Specify encoders and feedback for turrets and remote weapon stations →
Rugged servo drives for 28 V turret axes
Turret drives draw high peak current during fast slews from a 28 V vehicle supply full of surges, spikes and cranking dips. MIL-STD-1275E sets 20 to 33 V steady state and an injected ±250 V spike test, so size the drive input stage, filtering and any energy storage for both the supply events and the load peaks. The stabilisation loop needs a fast current loop, low current noise and enough peak current for disturbance rejection. Specify the feedback interfaces, network (CAN, RS-422 or EtherCAT), temperature range and conformal coating. High-current PWM drives inside a turret are a strong emission source under MIL-STD-461 or DEF STAN 59-411.
- Remote weapon stations: high-current azimuth and elevation drives
- Turret traverse: vehicle-power servo drives
- Stabilised mounts: high-bandwidth current control
- Fixed-site and naval mounts: rugged drive modules
Available through our supply network
All servo drives →Specify servo drives for turrets and remote weapon stations →
Low-voltage servo motors for geared turret axes
Geared turret axes use housed brushless servo motors driving through the reduction, which keeps the motor small and makes a sealed unit easier to qualify than a frameless kit. Choose a winding for the vehicle bus and check torque at the bottom of the steady-state voltage band, not at nominal. Specify a power-off brake for parking and transport, the shaft seal and IP rating, connector type, finish, temperature range and the feedback type the drive expects. Low-cogging designs help slow, smooth motion. Commercial low-voltage servo motors are a starting point; the programme then adds its own environmental, EMC and shock qualification and configuration control.
- Geared turret traverse: servo motor on the pinion drive
- Elevation drives: compact geared motors with brakes
- Auxiliary axes: covers and sensor shutters
- Training and test rigs: representative drive axes
Available through our supply network
All servo and stepper motors →Specify servo and stepper motors for turrets and remote weapon stations →
Standards to have in view
- MIL-STD-810H (environmental engineering and laboratory tests)
- MIL-STD-461H (control of electromagnetic interference; supersedes MIL-STD-461G)
- MIL-STD-1275E (28 V DC input power to utilisation equipment in military vehicles)
- DEF STAN 00-35 (environmental handbook for defence materiel)
- DEF STAN 59-411 (electromagnetic compatibility)
- MIL-STD-1553 (digital time division command/response multiplex data bus)
Which standards apply depends on the end product and its market. Your engineer will confirm what the component itself needs to meet.